Medical imaging · Computational mechanics · Machine learning
Physics-Informed Brain MRI Registration Longitudinal deformation modeling using Neural ODEs.
A computational research project for aligning longitudinal 3D brain MRI scans and estimating how regional brain tissue deforms over time. The pipeline combines medical-image segmentation, signed distance fields, continuous Neural ODE transformations, physics-informed correction, and region-based evaluation.
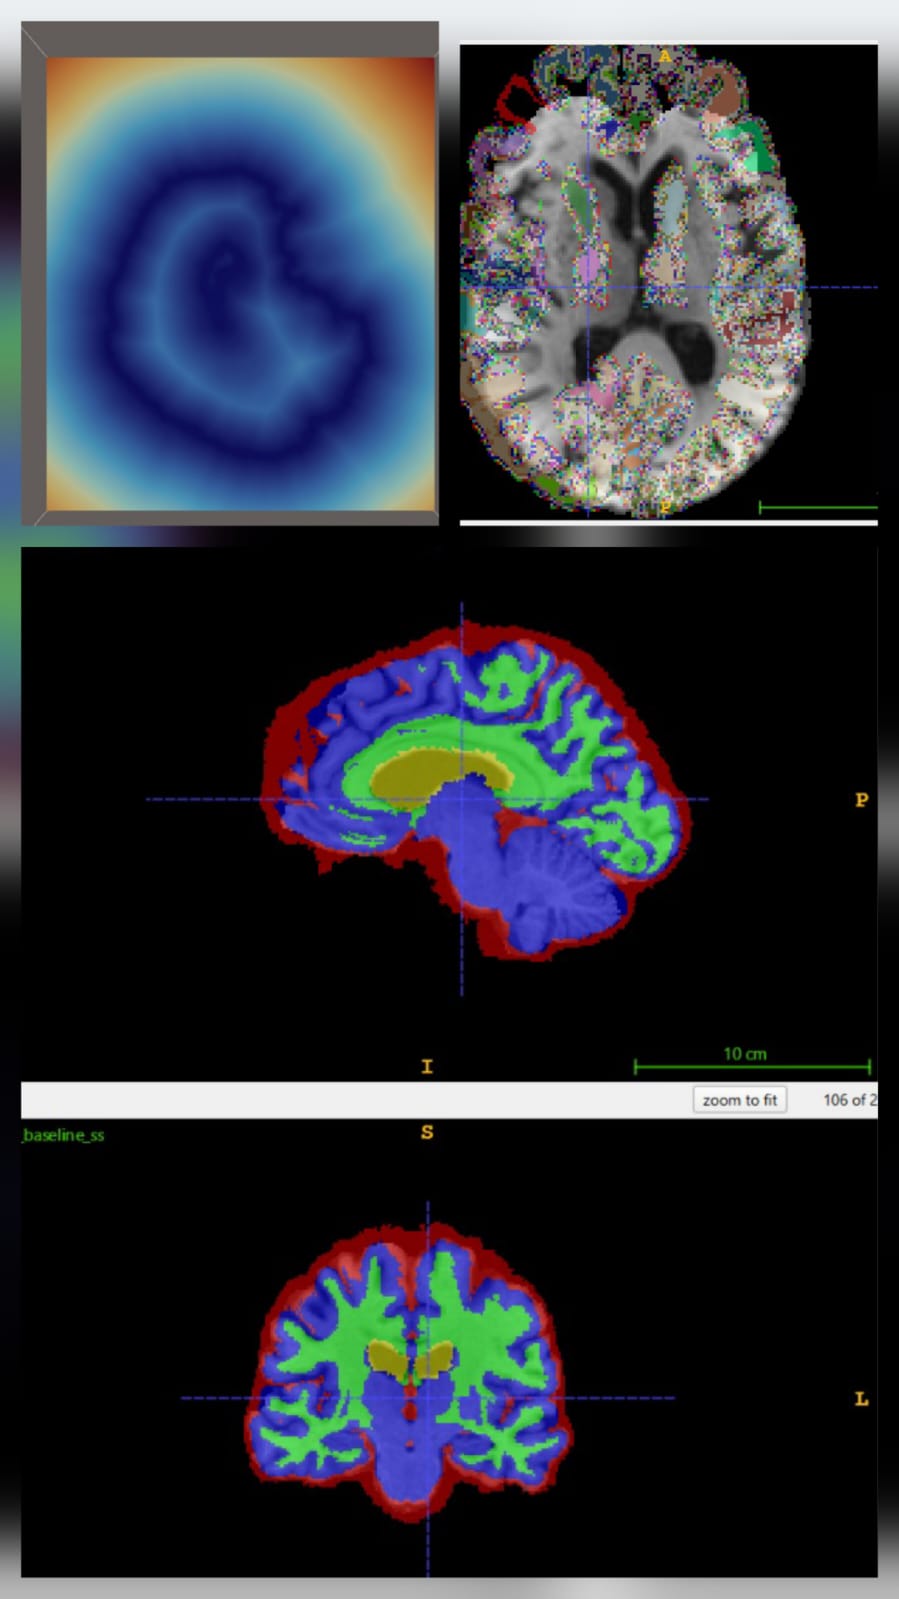
Load baseline and follow-up volumes with regional segmentation masks.
Convert anatomical regions into geometric representations for deformation analysis.
Model spatial transformation as a continuous deformation process.
Warp labels and measure registration quality using regional overlap.
01 / Problem
Longitudinal brain scans must be aligned before tissue changes can be measured.
Brain MRI scans collected at different time points do not naturally share perfect anatomical alignment. Differences in patient positioning, image acquisition, anatomy, and tissue change make direct voxel-to-voxel comparison unreliable.
The registration system must estimate a spatial transformation that aligns corresponding anatomical regions while still representing realistic tissue deformation.
This becomes especially challenging when the objective is to quantify subtle regional shrinkage rather than simply produce visually similar images.
02 / Registration Pipeline
From longitudinal MRI volumes to measurable deformation.
The pipeline processes baseline and follow-up T1 MRI volumes together with regional segmentation masks. Anatomical boundaries are extracted from the segmentations and represented using signed distance fields.
A Neural ODE model estimates a continuous transformation between the scans. The resulting deformation is used to warp boundaries and segmentation labels into a common coordinate frame.
Prepare the longitudinal scan pair.
Load the baseline scan, follow-up scan, and corresponding regional segmentation labels.
Convert regional masks into boundaries.
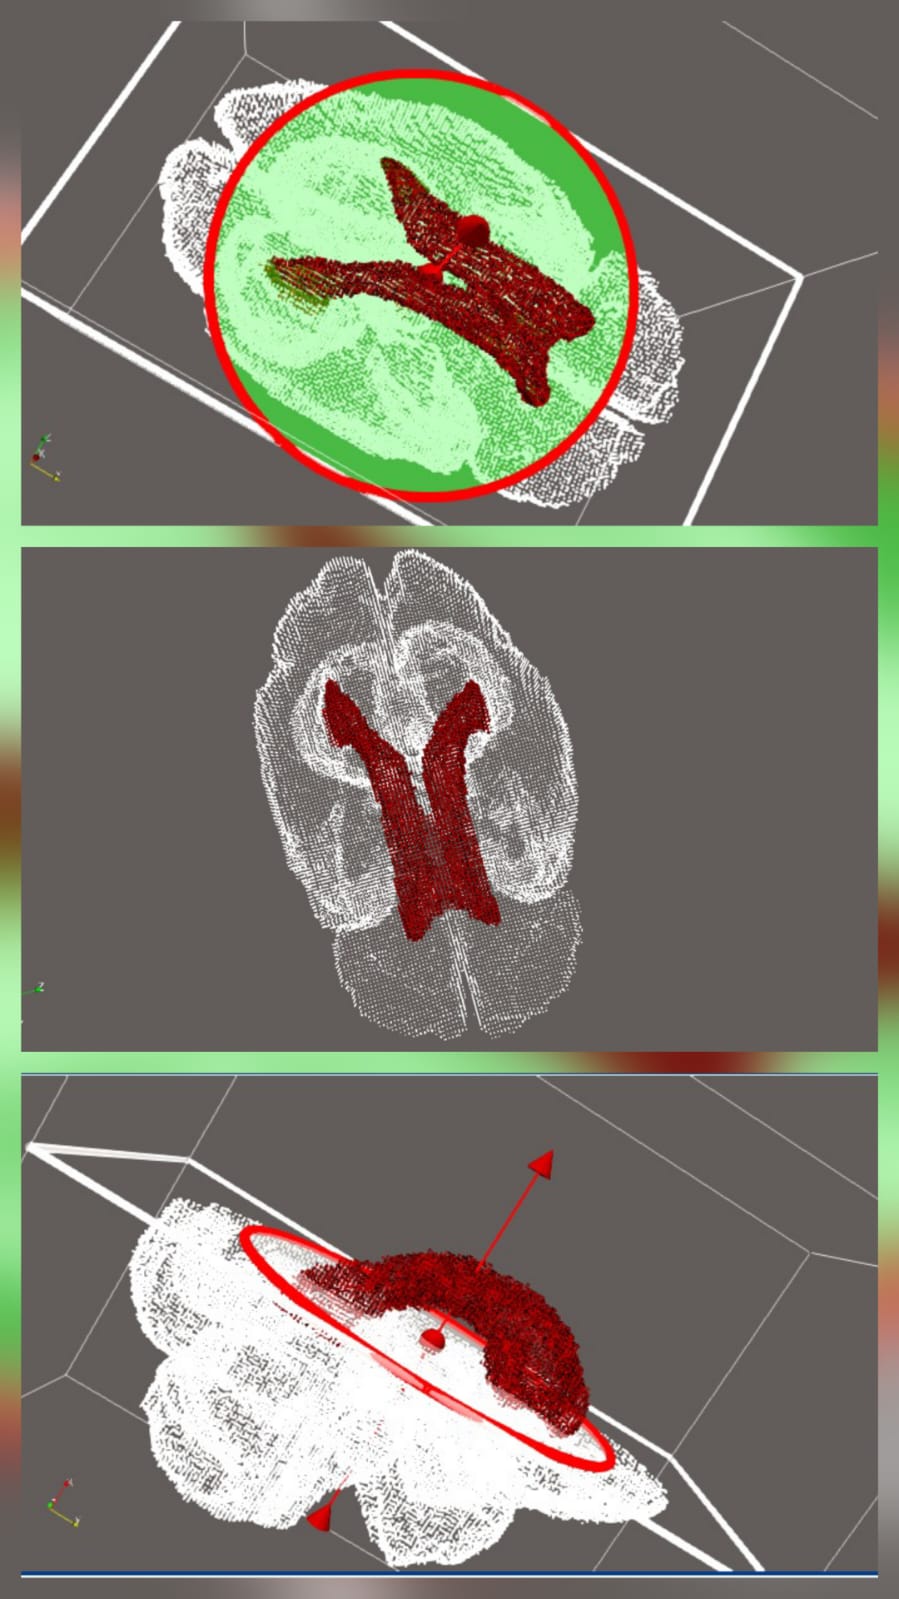
Extract anatomical surfaces and boundary points from segmented brain regions.
Estimate the continuous deformation field.
Use the Neural ODE transformation to map coordinates between longitudinal scans.
Measure regional registration quality.
Warp segmentation labels and compare anatomical overlap using quantitative metrics.
03 / Geometric Representation
Signed distance fields convert anatomy into usable geometry.
Segmentation masks identify anatomical regions as discrete voxel labels. Boundary extraction converts those regions into geometric surfaces that can be transformed and compared.
Signed distance fields encode the distance from each location to a regional boundary while preserving whether the location lies inside or outside the structure. This creates a smooth geometric representation for registration and physics-informed correction.
Three-dimensional boundary visualizations are used to inspect the position and orientation of internal and external anatomical structures before applying the deformation model.
04 / Neural ODE Model
Model deformation as a continuous transformation.
A Neural Ordinary Differential Equation represents the coordinate transformation through continuous dynamics rather than predicting a complete displacement in one step.
The model defines how spatial points move through an artificial time variable. Integrating these dynamics produces a deformation field that maps anatomical coordinates between the baseline and follow-up scans.
This formulation supports forward deformation, inverse mapping, boundary warping, and visualization of how regional anatomy changes across time points.
05 / Physics-Informed Correction
Image similarity alone does not guarantee realistic motion.
A registration model can produce strong intensity alignment while still creating spatial transformations that are difficult to interpret physically.
Physics-informed correction introduces model-based information into the deformation pipeline. The objective is to preserve meaningful geometry, reduce unrealistic deformation, and improve the interpretation of regional tissue motion.
Combining learned transformations with geometric and physical constraints makes the resulting deformation field more useful for longitudinal tissue analysis.
06 / Evaluation
Validate the transformation using anatomical labels.
Registration quality is evaluated by applying the estimated transformation to regional segmentation labels and comparing them with the target anatomy.
Dice scores measure the spatial overlap between the warped and target regions. Regional evaluation is important because a visually plausible whole-brain alignment may still contain local errors around individual structures.
Visual inspection of warped boundaries complements the quantitative scores by revealing incorrect coordinate directions, local distortions, or failures around anatomical interfaces.
07 / Research Contribution
Building and debugging a complete research pipeline.
My work involved developing and debugging components for longitudinal brain-data processing, segmentation handling, boundary extraction, signed distance field construction, deformation visualization, inverse coordinate mapping, and quantitative registration evaluation.
The work also involved running experiments on GPU computing infrastructure, tracing shape and coordinate inconsistencies, inspecting intermediate outputs, and validating whether transformations were being applied in the correct spatial direction.
Prepare longitudinal imaging data.
Work with volumetric scans, segmentation masks, regional labels, and derived geometric data.
Trace spatial and computational errors.
Inspect array shapes, coordinate conventions, transformation direction, and intermediate outputs.
Make deformation behavior interpretable.
Visualize boundaries, warped regions, deformation fields, and longitudinal alignment.
Quantify regional performance.
Compare warped and target segmentation regions using repeatable quantitative metrics.
08 / Robotics Relevance
Registration shares core geometric ideas with robotics.
Although the application is medical imaging, the pipeline shares several core problems with robotic perception and spatial estimation. These include coordinate-frame reasoning, correspondence estimation, geometric transformations, boundary processing, forward and inverse mapping, and quantitative comparison between predicted and observed geometry.
Deformation fields extend these ideas beyond rigid-body motion. This is relevant to deformable-object tracking, surgical robotics, soft robotics, non-rigid mapping, simulation validation, and model-based perception.
09 / Technologies